It has been two months since my last update and it feels like things are progressing. It is still going slower than I would like, but I think that is mostly because I am very impatient! Tinkibot is slowly starting to feel less like a prototype and more like a product, and version 1 finally feels quite close.
I am now on the second iteration of both the processor board and the top board. Testing the first versions highlighted a few problems, which I have hopefully now fixed, and so far the new boards seem to be working really well. There is always that slightly nervous moment when you power up a new board for the first time, so seeing them actually work is a great feeling.
A Smaller Tinkibot
The new processor board is much smaller than the original version, which relied on development modules. Moving everything onto my own board has freed up quite a bit of space inside Tinkibot. This means I might finally be able to reduce the overall height of the robot, which is something I have wanted to do for a while.
Tinkibot ended up a little taller than I originally planned simply because I had to fit a lot of electronics into a very small space. It is amazing how quickly you run out of room when you are trying to squeeze everything into an 80mm square robot! With the smaller boards, I should have a bit more freedom to change things.
Buttons, Lights and Games
As part of the redesign of the top board, Tinkibot now has four fully functioning buttons. Each button has an LED behind it which can be controlled programmatically, and the buttons have different symbols on them too.
My thinking was that these could be great for programming simple games. You could create a memory game where Tinkibot flashes a sequence of symbols and you have to copy them, for example. They could also be used for quizzes, controls or whatever else students can come up with.
That is something I really want Tinkibot to encourage. Rather than every feature having one specific purpose, I want there to be lots of opportunities to experiment and find different ways of using things.
Changes Underneath
The bottom of Tinkibot has also had quite a big redesign. There is now a row of sensors underneath the robot which will allow students to program it to follow lines and detect what is underneath it.
Line following is the obvious use, but I think there could be some more unusual things we can do with the sensors. One idea I would really like to try is turning Tinkibot into a simple scanner. You could draw an image on paper and then program the robot to move across it, using the sensors to recreate the image on the Scratch canvas.
I have no idea how well that will work yet, but experimenting and finding out is part of the fun.
The USB socket and power switch have moved into the base too. This has allowed me to integrate them into the power supply board, which should make assembling the robots much easier when I eventually get to the point of manufacturing them.
Unfortunately, the power supply board is only on its first iteration and it still has a few issues that need ironing out. That is a little frustrating, especially when the other boards are working well, but designing new electronics rarely works perfectly the first time. Hopefully the next version will get me much closer.
Tinkimo Has Been Changing Too
It isn’t just Tinkibot that has been getting some attention over the last couple of months. I have also spent quite a lot of time updating the Tinkimo website and trying to make the overall vision a bit clearer.
There is still a long way to go and plenty that I want to add, but I think it is heading in the right direction. I want the website to explain not just what Tinkibot is, but what I am trying to achieve with Tinkimo and how people can get involved.
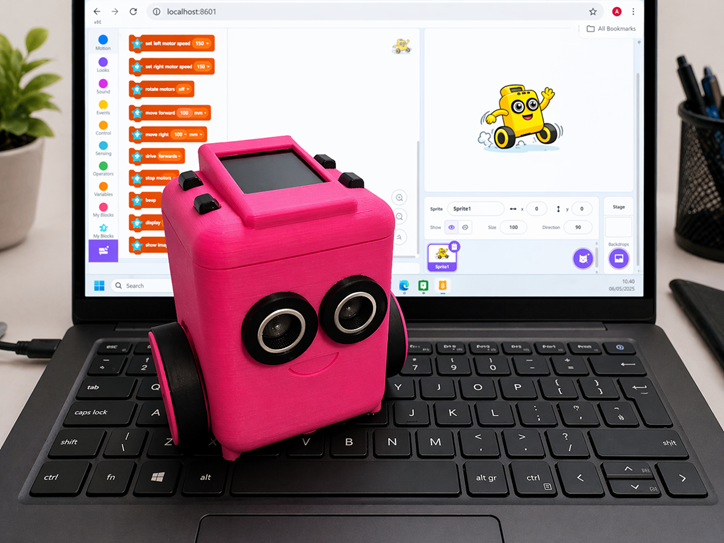
One of the biggest things I wanted to achieve was getting the Tinkiblocks editor onto the website, and that is now working. Tinkiblocks is based on the popular Scratch platform, so it provides a familiar block programming environment for controlling Tinkibot.
Once the robots are ready, students will be able to open the editor in their browser and start programming them. Getting to the point where the robot and the programming environment are starting to come together feels like quite a big milestone.
Getting Tinkibot Into People’s Hands
My next step is to start reaching out to schools, organisations, teachers and other people who might be interested in what I am building. I would really like to take a working Tinkibot along, let people experiment with it and see what they think.
There are lots of things I want to learn from doing this. I want to know what people like, what they find confusing and what they would change. I also want to start getting feedback on the idea of schools renting Tinkibots rather than necessarily having to buy them.
Before I can properly start doing that, though, I need to create some lessons and activities that students can actually try. Building the robot is only one part of Tinkimo. Creating useful resources that make it easier for teachers to use the robots is just as important.
And Then There Is the Biscuit…
I have also been thinking about something new. A conversation I had recently, along with several posts I have seen about creating extensible platforms, got me thinking about how Tinkibot could be expanded in the future.
This has led to something I have been calling the Biscuit.
The idea is to have a section at the top of Tinkibot that can be added, removed or replaced. Instead of the capabilities of the robot being completely fixed, students, teachers, tinkerers and creators could add something new and experiment with it.
For example, you could have a Biscuit containing a camera. That could allow students to experiment with computer vision and perhaps program Tinkibot to recognise or move towards different objects. Another Biscuit could contain stereo microphones and allow experiments with sound and detecting where noises are coming from.
There are probably lots of other possibilities I haven’t thought of yet, and that is actually one of the things I like most about the idea. I would love to get to the point where other people are creating things for Tinkibot that I would never have thought of myself.
The Biscuit is still very much an idea at the moment, but then not that long ago Tinkibot itself was just an idea.
Hopefully the Plan Is Coming Together
There is still plenty to do. I need to sort out the power supply board, continue working on the hardware, create lessons and start getting Tinkibot in front of teachers and students.
But when I look back at where things were a few months ago, it does feel like all the different pieces are starting to come together. I now have custom circuit boards, buttons, controllable LEDs, line sensors and a browser based programming environment. Tinkibot is starting to become the thing I originally imagined rather than just a collection of prototypes on my desk.
There will undoubtedly be more problems to solve, more circuit boards to order and probably a few more ideas that send me off in unexpected directions. That is all part of building something like this.
I am starting to feel a little like Hannibal from The A-Team.
Hopefully the plan is coming together!
It has certainly come a long way from the “I’ve got an idea…“ stage.